Systems Pipeline Data & Deployment · 2026
Teleop Pipeline
Teleoperation and Robot Learning Data Pipeline
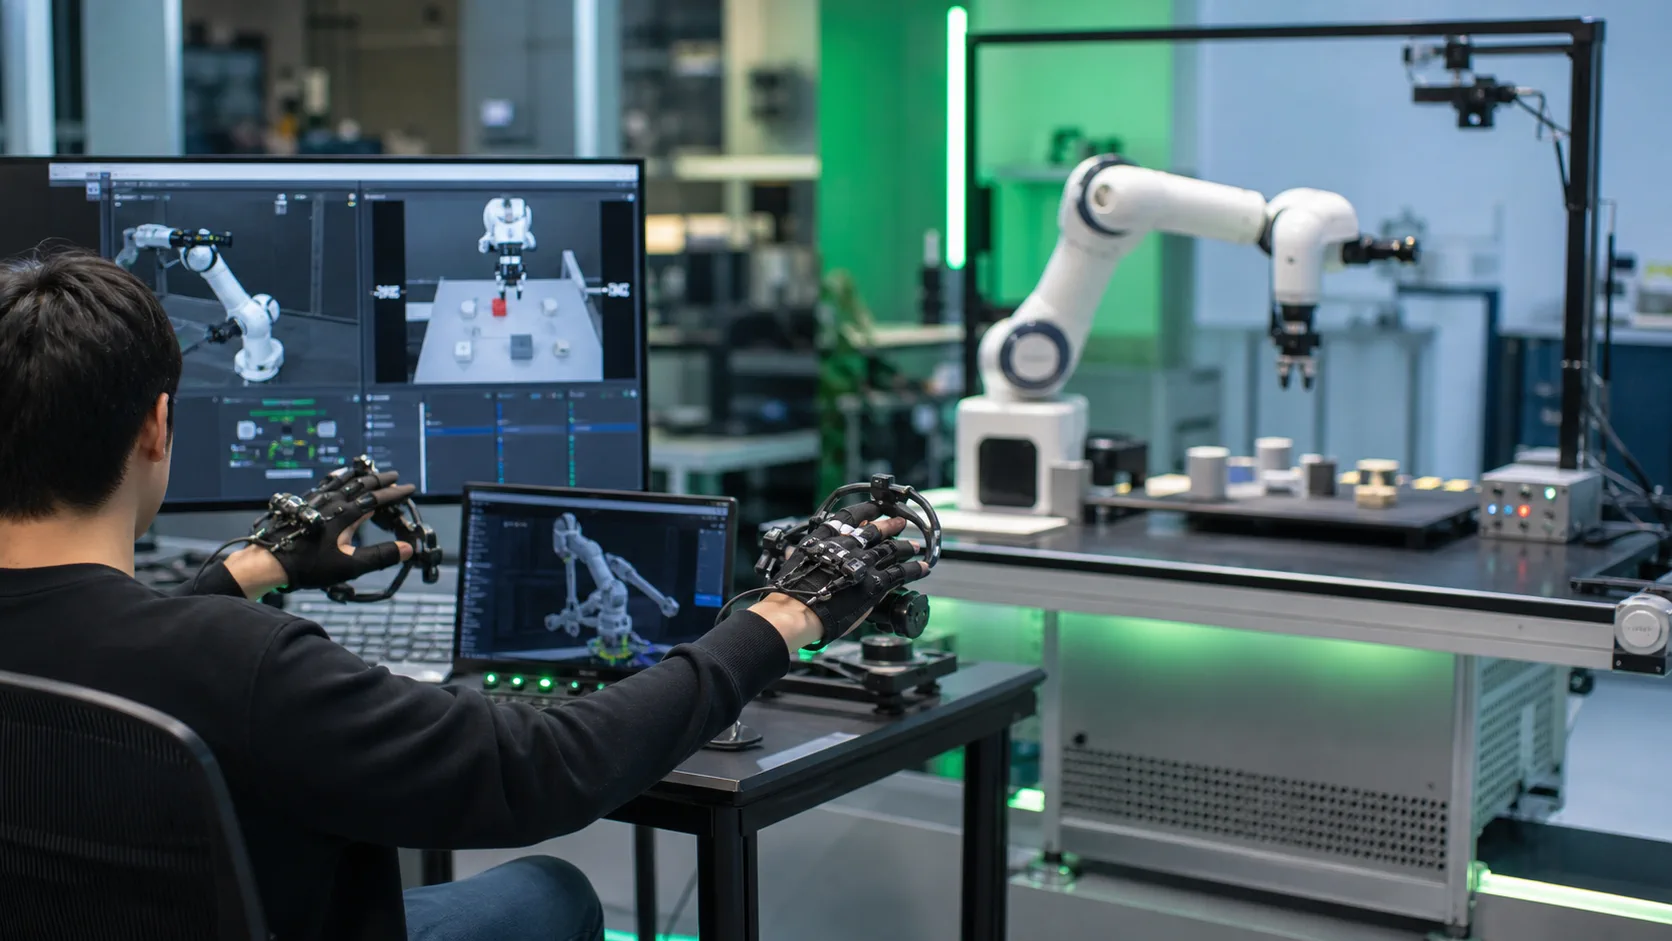
A compact public overview of the interfaces used to operate ALLEX, observe robot state, and prepare demonstrations for learning experiments.
01
What I Did
- Iterated on a 7-DoF master-device interface and operator workflow for ALLEX-oriented teleoperation.
- Connected ROS 2 state streams, live robot visualization, and simulation/real-robot validation paths.
- Supported retargeting and dataset logging for downstream imitation-learning experiments.
Detailed hardware specifications and internal control implementation are intentionally omitted.
02
Topics · Project Details
Focus
Master-device interfaces and demonstration-data workflow support
Topics
TeleoperationRobot LearningDataset LoggingROS 2
Stack
ROS 2PythonIsaac Sim
Details
- Track
- Data & Deployment
- Stage
- Graduate
- Year
- 2026
- Status
- Current